Control systems
Communication protocols of control systems
By Preeti Raskar, B.Tech (Instru), MBA (IB), MIE, CE. Business Owner, Ryka Engineering Solutions.
In an operating plant, the more operating process data it gives, the better the monitoring and control of the processes, and the lead indicators result in minimal downtime. This has a direct relation to production volumes and yields, and to improved financial results. This running plant parameter feedback is provided by different instruments working on different technologies. These instruments not only communicate the plant data to the central control system but also provide their self-health status data. The field of industrial communications is continuously developing at an astonishing pace to cater to the needs of industry. It has evolved from pneumatic to electrical communications, and technological developments have enabled the industry to move from digital communication to a wireless mode of communication.
This effort is towards addressing the communications and will briefly cover:
- Communication basics
- Serial communication and its basic standards
- Communication protocols:
- MODBUS
- HART
- DeviceNet
- ASIbus
- PROFIBUS
- FOUNDATION Fieldbus
- Overall comparison of communication protocols
- Wireless network
- Engineering approach
1. Communication basics
Have you ever experienced communicating with a person who did not know your language, without the help of an interpreter?
You must have struggled to convey the message with some gestures, and it must have created a funny situation.
In order to communicate with each other, the sender and receiver have to agree on the “language or format” of communication.
A communication protocol is a system, set of rules or definite format that allows two or more entities to transmit and receive information. These are the rules or standards that define the syntax, semantics and synchronization of communication and the possible error recovery methods.
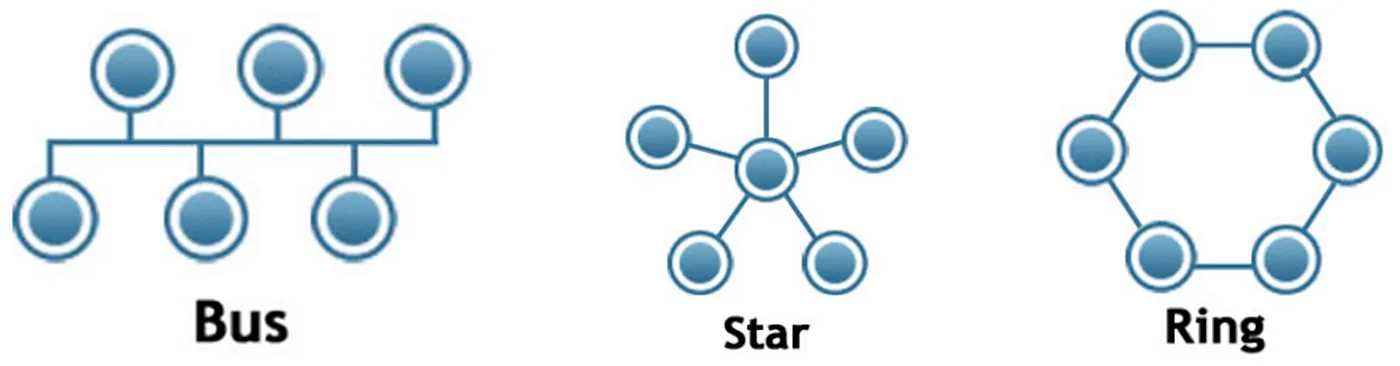
A communication protocol is a function of three important entities: the physical layer, the transmission media and the network topology.
The physical layer of the communication defines how data is physically transported from device to device.
Transmission media means the cables used in the communication, which are the backbones of networks. There are three types of cables: twisted pair cables, co-axial cables and glass fibre cables.
The network topology describes the way in which the devices in the network are connected together. The basic topologies are star, ring and bus arrangements, as shown below:
2. Serial communication and its basic standards
Serial communication is the process of sequentially sending one bit of data at a time. This is a two-way (full duplex) type of communication. The transmission media of this communication needs a minimum of only three separate wires: one to send, one to receive, and a common signal ground wire.
Basic standards
RS-232 is the oldest standard for serial communication transmission of data (RS stands for recommended standard). RS-232 is commonly used in computer serial ports. RS-232 allows data transfer at relatively slow speeds (up to 20K bits/sec) and short distances (up to 50 ft.). RS-232 has the limitations of slow speed, noise and non-detection of errors.
RS-485 is the next commonly used standard for serial communication transmission of data. It offers data transmission speeds of 35 Mbit/s up to 10 m and 100 Kbit/s at 1200 m. Since it is differential, it resists electromagnetic interference from motors and welding equipment.
In the RS-485 communication standard, the recommended arrangement of the wires is point-to-point (multidropped) nodes, i.e. a line or bus, not a star or ring network. It also recommends a termination resistor at the two ends of the cable, connected across the two wires. Without termination resistors, multiple data edges are created that can cause data corruption. Termination resistors also reduce electrical noise sensitivity. The value of each termination resistor should be equal to the cable characteristic impedance (typically 120 ohms for twisted pairs). In this communication, 32 nodes (masters or slaves) can be connected to a single segment. If more than 32 nodes are required, repeaters may be used.
Serial communication as per RS-485 is used while communicating with RTUs and PLC/DCS to transmit and receive non-critical data bits. RS-485 is also used as the physical layer of Modbus and Profibus DP.
3. Communication protocols
3.1 MODBUS
Origin: MODBUS is a serial communication protocol developed by Modicon in 1979.
Physical layer: For the MODBUS protocol, the physical layer is not defined, hence RS-232, RS-485 or a current loop are generally used based on the required transmission rates.
Transmission media: In MODBUS, the data is transported serially via a minimum of three wires: one to send, one to receive, and a common signal ground wire.
Network topology: In MODBUS, the recommended topology is bus.
Design basics: The device requesting the information is called the MODBUS Master and the devices supplying information are MODBUS Slaves. In a standard MODBUS network, there is 1 Master and there can be up to 247 Slaves.
A typical MODBUS segment consists of:
- Devices having a MODBUS port/output
- 3-wire or shielded pair cable with the required mating connectors
- Terminating resistors
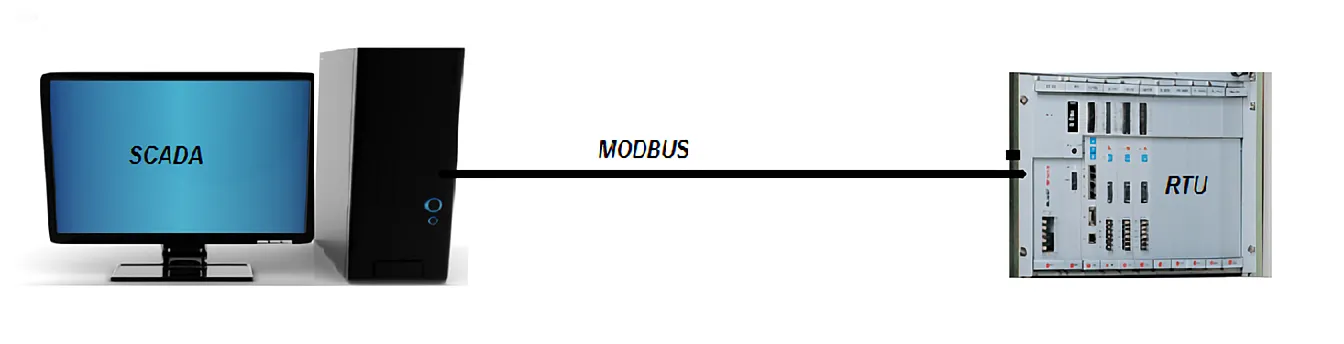
Application: MODBUS is an open protocol. MODBUS is often used to connect a SCADA with a remote terminal unit (RTU) in SCADA systems. Versions of the Modbus protocol exist for serial lines (Modbus RTU and Modbus ASCII) and for Ethernet (Modbus TCP/IP).
3.2 HART
Origin: It was introduced by the HART Communication Foundation in 1989.
Physical layer: The data is transported via a standard current loop by HART-compatible instruments.
Transmission media: The transmission media is the shielded pair cable used for a standard current loop.
Network topology: A special network topology is not applicable; it requires a point-to-point connection.
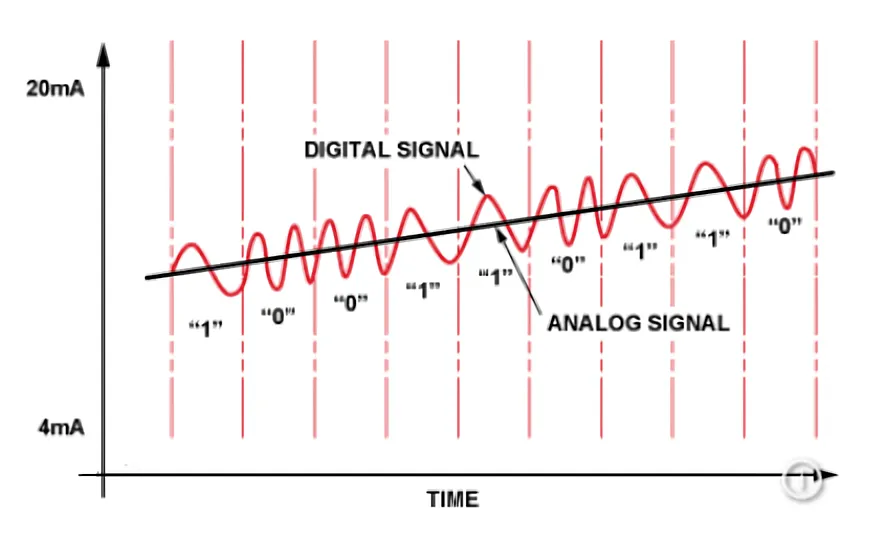
Design basics: HART provides value-added information about the device and its diagnostics in digital form, while retaining compatibility with 4-20 mA standard current loop automation architectures. As it consists of analogue and digital communication, HART is also called a hybrid protocol. The digital information is carried by a low-level modulation superimposed on the standard 4-20 mA current loop. The digital signal does not affect the analogue reading because it is removed from the analogue signal by standard filtering techniques.
The HART digital communication signal is superimposed on the analogue 4-20 mA signal as below:
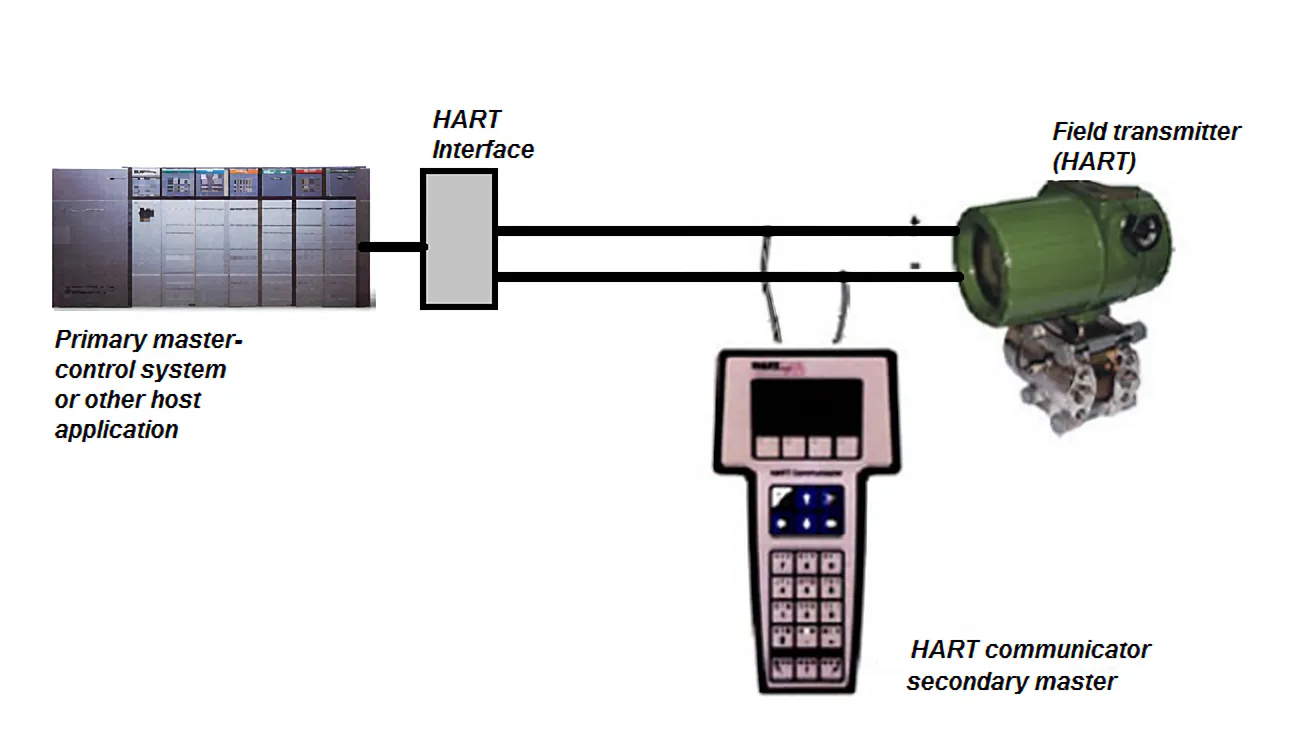
HART is principally a master/slave protocol, which means that a field (slave) device speaks only when a request is received from a master. Two masters (primary and secondary) can communicate with slave devices in a HART network. Secondary masters, such as handheld communicators, can be connected almost anywhere on the network and communicate with field devices for calibration or diagnostic purposes without disturbing communication with the primary master. A primary master is typically a DCS, PLC, or computer-based central control or monitoring system.
A typical HART loop consists of:
- Devices having HART output
- Shielded pair cable
- HART communicator (a tool to configure the device remotely)
- HART management software with computer (a tool to configure the device from the control room, if required by the client)
Application: Due to the value-added device diagnostic information and calibration facility, and the authentic 4-20 mA current loop, HART is the most commonly used protocol in process plants. The HART protocol saves time and resources while troubleshooting and maintaining the plant. It provides easy start-up and commissioning of the plant.
3.3 DeviceNet
Origin: DeviceNet was originally developed by the American company Allen-Bradley in 1990 (now owned by Rockwell Automation). It is an application layer protocol on top of the CAN (Controller Area Network) technology developed by Bosch.
Physical layer: The data is transported via two pair cables with the help of gateways and repeaters as required.
Transmission media: The transmission media is shielded, twisted two pair cable (one pair for 24 V power and the other pair for communication). There are 4 types of standard DeviceNet cables: thick, medium, thin and flat.
Network topology: DeviceNet generally uses a bus type of network topology.
Design basics: In the DeviceNet communication protocol, cyclic as well as non-cyclic data is communicated. Cyclic data is the data sent periodically to the controller from devices such as sensors and actuators related to process control. Non-cyclic data is the data sent by the devices for device configuration and diagnostics, as requested by the master.
DeviceNet has a high network current capacity. A DeviceNet network may have up to 64 devices, with one device on each node, addressed from 0 to 63. Thick or thin cable may be used for trunk lines or drop lines. The network length varies with the data rate and cable length, as per the table below.
| Data rate | 125 Kbps | 250 Kbps | 500 Kbps |
|---|---|---|---|
| Length of main bus with thick trunk cable | 500 m | 250 m | 100 m |
| Length of main bus with thin trunk cable | 100 m | 100 m | 100 m |
| Maximum length of a main bus maximum drop | 6 m | 6 m | 6 m |
| Accumulated length of a main bus cumulative drop | 156 m | 78 m | 39 m |
A typical DeviceNet segment consists of:
- Devices having DeviceNet output/input
- DeviceNet cable with the required mating connectors
- Terminating resistors
- Suitable power supplies, gateways/converters and repeaters as required
Application: DeviceNet is generally used between industrial controllers and simple I/O devices like sensors and actuators.
3.4 ASIbus
Origin: The AS-Interface specification was developed in 1994 by AS-International, a member-funded non-profit organization located in Germany.
Physical layer: The data is transported via 2-wire cable with the help of gateways and repeaters as required.
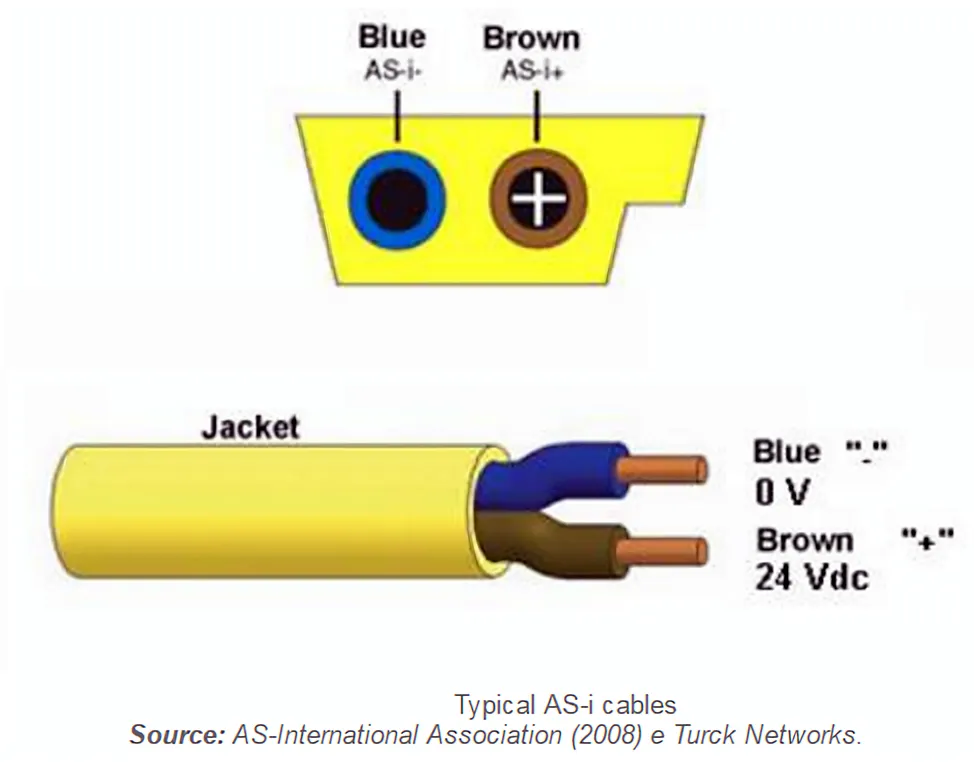
Transmission media: The ASIbus network cable is an unshielded 2-wire cable. The standard ASI cable available in the market is a flexible flat cable, which is suitable for use in non-hazardous areas in an open cable tray.
Network topology: Any type of network topology, i.e. bus, star or ring, is used in ASIbus.
Design basics: ASIbus (Actuator Sensor Interface bus) is an industrial networking protocol used for connecting simple field I/O devices (e.g. binary ON/OFF devices such as actuators, sensors, rotary encoders, push buttons and valve position sensors).
AS-Interface is an ‘open’ technology and is compatible with all common fieldbus systems. It is based on the master/slave principle. Unlike Profibus/Fieldbus networks, the AS-i network does not require equipment description files or terminating resistors.
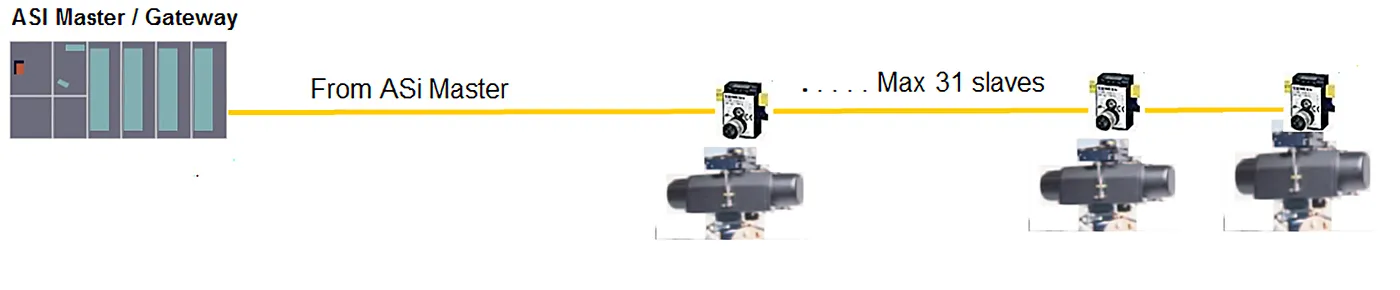
On ASIbus, a maximum of 31 devices (max. 248 digital inputs/outputs) can be connected on one bus. Each device can have 4 digital inputs and 4 digital outputs. The maximum length of the line segment is 100 m, and it can be extended to 300 m with the help of repeaters. The bus voltage is 26 to 31 VDC, and a separate power supply is required for the ASI master or repeater.
A typical ASI black flat cable is used to power the ASI master/repeaters.
The transmission rate of ASIbus is 167 Kbits/s.
A typical ASIbus segment consists of:
- Devices having ASIbus output/input
- ASIbus cable with the required mating connectors
- Suitable power supplies, gateways/converters and repeaters as required
The picture below shows a typical ASIbus segment:
Application: ASIbus is generally used between controllers and simple I/O devices like sensors and actuators.
3.5 PROFIBUS
Origin: Profibus technology was introduced in the early 1990s. The PROFIBUS DP and PROFIBUS PA technologies are specified in the international standards EN 50170 and IEC 61158.
Physical layer: The data is transported via pair cable with the help of couplers, gateways and repeaters as required. For Profibus DP, the physical layer is as per the RS-485 and IEC 61158 standards. For Profibus PA, the physical layer is as per the IEC 61158 standard.
Transmission media: Twisted pair, shielded (Type A) cable is generally used for Profibus communication.
Network topology: Any type of network topology, i.e. bus, star or ring, is used in Profibus.
Design basics: PROFIBUS is a standardized, open communications system for all areas of application in factory and process automation. There are two types of Profibus protocol: Profibus DP and Profibus PA.
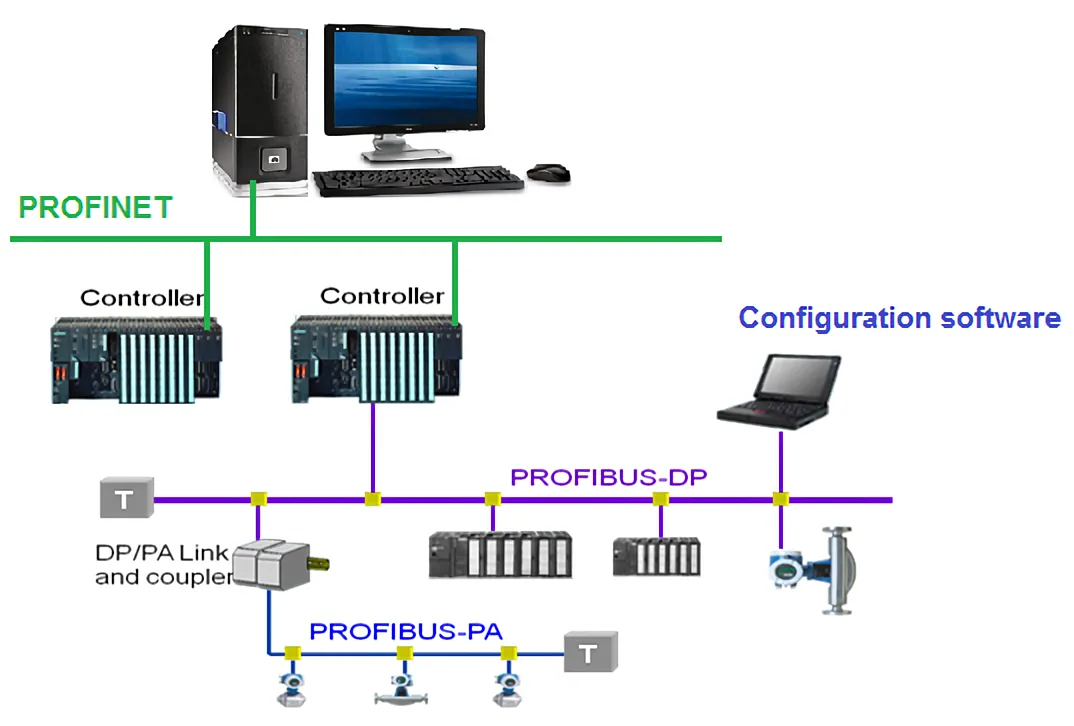
PROFIBUS DP (Decentral Periphery) is generally used for the electrical and sensor interface. It is also used between the controller and I/O cards. There are three versions available in Profibus: DP-V0, DP-V1 and DP-V2. Of these, the most commonly preferred are DP-V1 and DP-V2. DP-V1 is for acyclic and cyclic data exchange and alarm handling. DP-V2 is for isochronous mode (i.e. data exchange at equal time intervals). The transmission rate of Profibus DP is up to 12 Mbit/s. On Profibus DP, max. 126 devices can be connected with repeaters, and a max. length of 1200 m can be covered with type A cable (it can go up to several kilometres with fibre optics).
PROFIBUS PA (Process Automation) is an extension of PROFIBUS DP, developed to cater to the requirements of process automation. PROFIBUS PA uses the DP-V1 protocol for communication at field level. The transmission rate of Profibus PA is up to 31.25 kbit/s. On Profibus PA, a max. length of 1200 m can be covered in a non-hazardous area and 1000 m in a hazardous area with type A cable (total length of segment = length of the trunk + length of all connected spurs).
The total number of devices connected on Profibus is a function of the total data value to be transmitted by each device, the current capacity of the segment coupler, the voltage requirement at each node, the data transmitting capacity of the Profibus masters/links, length limitations etc. Generally, as an average, a maximum of 6 devices are connected on one Profibus segment in a hazardous area with type A cable, and a max. of 15 devices are connected on one segment in a non-hazardous area with type A cable.
A PROFIBUS system requires a data description file of the device, i.e. output data, input data, data format and supported transmission rate, so that it can integrate the field devices into the bus system.
A typical Profibus segment consists of:
- Profibus-compatible I/O cards
- Devices having Profibus output/input
- Type A cable with the required mating connectors
- Terminating resistors
- Suitable Profibus couplers/links and repeaters as required
The picture below shows a typical Profibus architecture:
Application: Profibus DP is used between controllers and I/O cards/RTUs; it is also used for sensor/actuator and electrical interface applications. Some field instruments are available with Profibus DP output only, because of high power consumption. Profibus PA communication is generally used between the controllers and analogue I/O devices in process plants.
3.6 FOUNDATION Fieldbus
Origin: This open architecture was developed by the Fieldbus Foundation, based on IEC 61158, during 1995–1998.
Physical layer: The data is transported via shielded pair cable with the help of gateways and repeaters as required. The physical layer conforms to the ISA SP50.02 and IEC 1158-2 standards for fieldbuses.
Transmission media: Twisted pair, shielded (Type A) cable is generally used for Fieldbus communication.
Network topology: Any type of network topology, i.e. bus, star or ring, is used in Fieldbus.
Design basics: Foundation Fieldbus is an all-digital, serial, two-way communications system that serves as the base-level network in a plant or factory automation environment.
Two related implementations of Foundation fieldbus have been introduced to meet different needs within the process automation environment. These two implementations use different physical media and communication speeds.
- Foundation Fieldbus H1 operates at 31.25 Kbit/s and is generally used to connect field devices and host systems. It provides communication and power over standard stranded twisted-pair wiring in both conventional and intrinsic safety applications. H1 is currently the most common implementation.
- HSE (High-speed Ethernet) operates at 100/1000 Mbit/s and generally connects input/output subsystems, host systems, linking devices and gateways.
The communication method of fieldbus is client/server. The length of the fieldbus is determined by the communication rate, the cable type and the voltage required at the last node. However, the maximum distance covered by an H1 segment is 1900 m, and by an HSE segment 100 m. The permissible data size depends upon the card used; according to the Fieldbus standard, it can transmit or receive 246 bytes.
The total number of devices connected on a Fieldbus H1 network is a function of the total data value to be transmitted by each device, the current capacity of the H1 card, the minimum operating voltage requirement at the last node, the data transmitting capacity of the gateway/I/O cards, length limitations etc. Generally, as an average, a maximum of 6 devices are connected on one Fieldbus segment in a hazardous area with type A cable, and a max. of 15 devices are connected on one segment in a non-hazardous area with type A cable.
A typical Fieldbus segment consists of:
- Fieldbus-compatible I/O cards
- Devices having Fieldbus output/input
- Type A cable with the required mating connectors
- Terminating resistors
- Suitable H1 cards, linking devices/gateways, power supplies and repeaters as required
There are four types of cable that can be used for Fieldbus. Type A cable is the most preferred for new installations because it allows for the most versatile lengths. The other types of cable are for installations where cable already exists from 4-20 mA systems. See the table below:
| Cable type | Description | Size | Max. length |
|---|---|---|---|
| A | Shielded, twisted pair | #18 AWG (0.8 mm²) | 1900 m |
| B | Multiple twisted pair with shield | #22 AWG (0.32 mm²) | 1200 m |
| C | Multiple twisted pair without shield | #26 AWG (0.13 mm²) | 400 m |
| D | Multi-core, without twisted pairs and having an overall shield | #16 AWG (1.25 mm²) | 200 m |
A typical Fieldbus H1 network segment is as below:
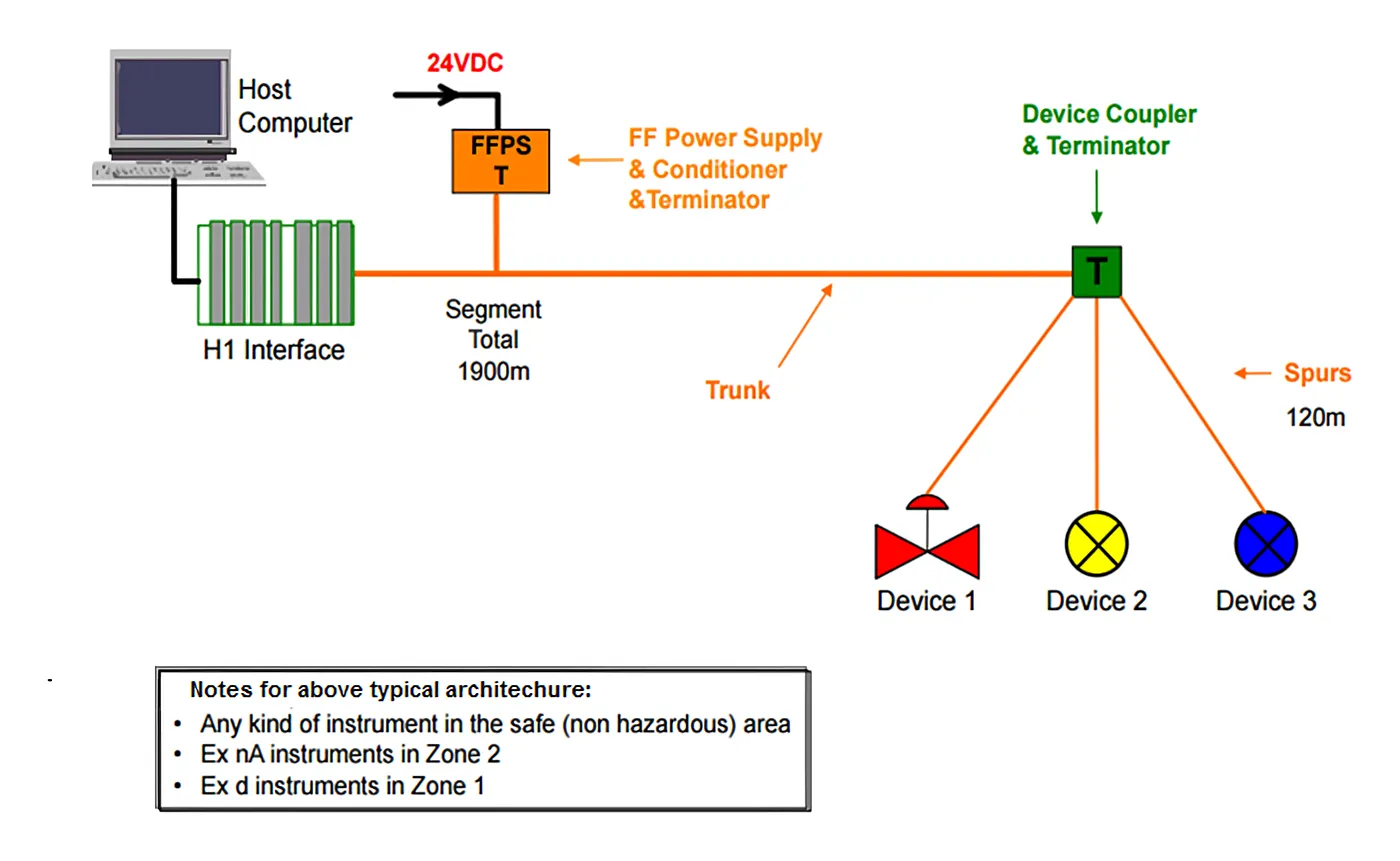
A Foundation Fieldbus system requires a data description file of the device so that it can integrate the field devices into the bus system.
Application: Foundation Fieldbus technology is mostly used in process industries.
3.7 Overall comparison of communication protocols
| Description | MODBUS | HART | DeviceNet | ASIBUS | PROFIBUS | FOUNDATION FIELDBUS |
|---|---|---|---|---|---|---|
| Applicable standards | RS-232, RS-485 | – | – | – | IEC-61158, IEC-61784, EN 50170 | IEC-61158, ISA SP50.02 |
| Transmission media | 3 wires | Shielded pair cable | Two pair, shielded DeviceNet cable | Unshielded pair cable | Twisted pair, shield cable (Type A) | Twisted pair, shield cable (Type A) |
| Type of network topology | Bus, ring | Point to point | Bus | Bus/star/ring | Bus/star/ring | Bus/star/ring |
| Speed | 35 Mbits/s for 10 m, 100 Kbits/s for 1.2 km | 100 bits/s | 125/250/500 Kbits/s (based on cable selection) | 167 Kbits/s | Profibus DP: 12 Mbits/s; Profibus PA: 31.25 Kbits/s | Fieldbus HSE: 100/1000 Mbits/s; Fieldbus H1: 31.25 Kbits/s |
| Maximum length of typical one segment | 10 m – 1.2 km | 200 m | 500 m | 100 m without repeater, 300 m with repeater | Profibus DP: 1200 m without repeater (RS-485); Profibus PA without repeater: 1200 m in non-hazardous area, 1000 m in hazardous area | Fieldbus HSE: 100 m; Fieldbus H1: 1900 m |
| Bus voltage | Voltage-free contacts, 24 VDC | 24 VDC | Voltage-free contacts, 24 VDC | 26 to 31 VDC | Profibus PA: 9 to 32 VDC | Fieldbus H1: 9 to 32 VDC |
| Total no. of devices on one segment (as an average, approx.) | 32 (without repeater) | Not applicable | 64 | 31 | Profibus DP: 126; Profibus PA: 6 in haz. area, 12–15 in non-haz. area | Fieldbus H1: 6 in haz. area, 12–15 in non-haz. area |
| Segment requirements: | ||||||
| Requirement of termination resistor | Required | Not applicable | Required | Not required | Required | Required |
| Other devices requirement | MODBUS-compatible devices, addressing tool | HART-compatible devices, HART communicator | DeviceNet-compatible devices, addressing tool, suitable power supplies, gateways, connectors, repeaters as required | ASIBUS-compatible devices, addressing tool, suitable power supplies, gateways, connectors, repeaters as required | PROFIBUS-compatible devices, addressing tool, suitable power supplies, couplers/links/gateways, connectors, repeaters as required | Foundation Fieldbus-compatible devices, addressing tool, suitable power supplies, couplers/links/gateways, connectors, repeaters as required |
| Requirement of DDL file | Not required | Generally available by default in HART communicator | Not required | Not required | Required | Required |
| Application | To transmit/receive non-critical data, generally used for RTU to DCS interface | Generally preferred for safety shutdown system related I/Os and critical loops in process plants | Generally preferred for simple I/O devices like sensors and actuators | Generally preferred for simple I/O devices like sensors and actuators | Generally Profibus PA is preferred for non-critical analogue I/Os in process plants. Profibus DP is used for sensor and electrical interfaces, and between controllers and I/O cards/RTUs | Generally Fieldbus H1 is preferred for non-critical analogue I/Os in process plants |
4. Wireless network
The establishment of wireless technology for entire solutions is still in progress. Currently, wireless applications are available for monitoring. In the near future, wireless solutions for safety shutdown systems, for total control and for complex applications may be available.
The ISA100 committee of the International Society of Automation is responsible for the standardization and generation of guidelines for the implementation of wireless devices and systems for industrial applications.
Some manufacturers also follow the WirelessHART protocol, which is registered under IEC 62591. The IEC 62591 standard specifies guidelines for industrial networks, wireless communication networks and WirelessHART.
WirelessHART uses the 2.4 GHz frequency band, which is licence-free and used worldwide as a transfer medium for several radio technologies, including WLAN, Bluetooth etc.
For security purposes, every network has a unique network ID, and a device needs a join key before it can join the network. This join key can be common to every device on the network, or it can be unique to each device, creating an Access Control List (ACL).
WirelessHART uses a flat mesh network, where all radio stations (field devices) form a network. Every participating station serves simultaneously as a signal source and a repeater. The original transmitter sends a message to its nearest neighbour, which passes the message on until it reaches the base station and the actual receiver. In addition, alternative routes are set up in the initialization phase.
If the message cannot be transmitted on a particular path, due to an obstacle or a defective receiver, it is automatically passed to an alternative route. So, in addition to extending the range of the network, the flat mesh network provides redundant communication routes to increase reliability.
Like traditional HART, WirelessHART devices contain similar diagnostics to wired HART devices, or a subset of them. Diagnostic information is available through HART commands, and is also accessible through Device Descriptions (DD), either locally through a field communicator or remotely using asset management software.
A typical wireless mesh network is as below:
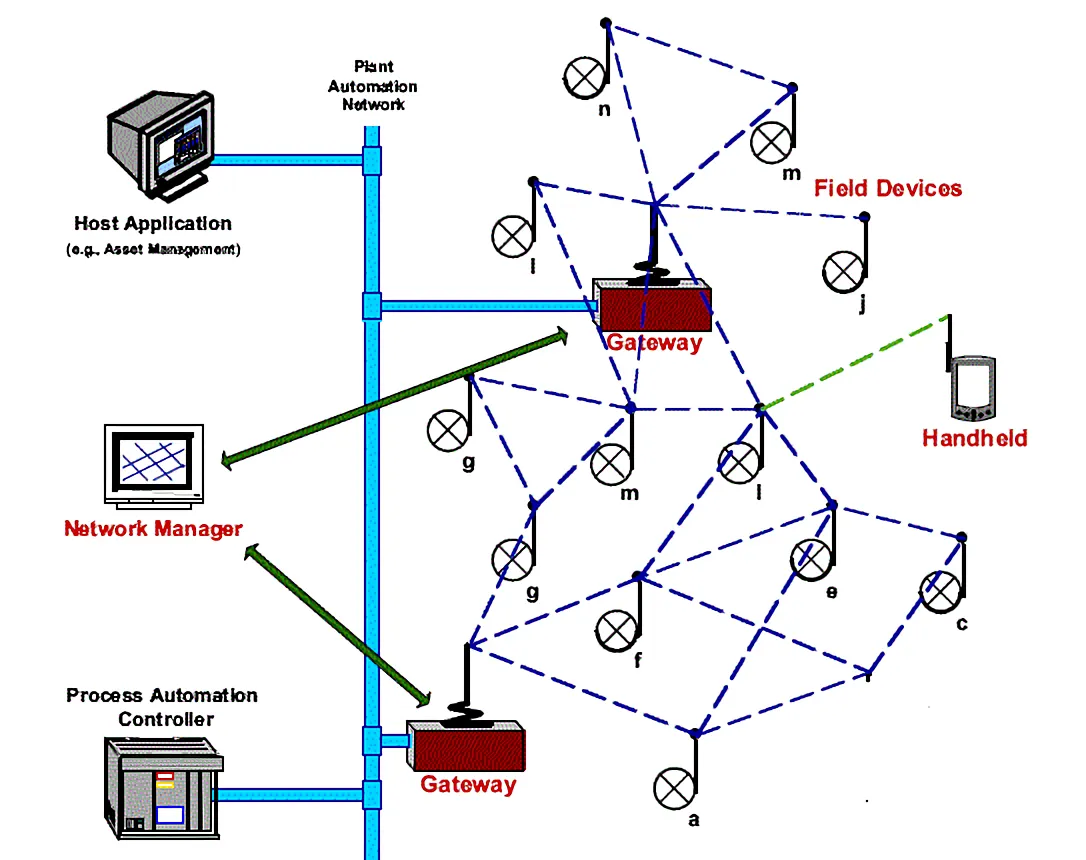
While designing wireless solutions, the functional, operational and infrastructure requirements need to be studied. This includes study of the design stage layouts and site visits, in order to map the field devices, identify the required number of wireless gateways/repeaters/adapters and their locations with respect to physical obstacles, estimate the cable length between the gateway and the system interface device etc.
For wireless field devices, along with the other required technical specifications, the specifications related to wireless communication need to be included, such as device battery life (based on the maintenance requirements, any remote location and the hazardous area class), update rates in seconds, and the communication type, i.e. ISA100 or IEC 62591. In the case of WirelessHART, the requirement for a WirelessHART handheld communicator to configure the devices needs to be considered.
The control system’s wireless-specific software, communication, redundancy, spare and expansion requirements also need to be identified at an early stage.
5. Engineering approach
In the oil and gas industry, such as in refineries and petrochemical plants, the processes and controls are highly complex. Due to optimized energy and resources, the need for ecologically sustainable development, the environmental performance of the plant and a competitive globalized economy, these processes have become more complex.
The increasing complexity of oil and gas process plant production systems demands fast and reliable process and condition monitoring, supervision, integrated diagnosis and suitable communication technologies, to achieve synergy among all the different subsystems and therefore increase plant performance, energy optimization, reliability, safety, sustainable development and global competitiveness. Due to these requirements, a typical oil refinery invests millions of dollars in the plant control system. It becomes the prime responsibility of engineering to select the suitable control system with the right communication protocols to cater to the needs of the plant.
Hence, during engineering, the factors below need to be considered while selecting the suitable control system with the correct communication protocols from the various options:
- Application of the control system, i.e. whether it is for shutdown, process plant, packages, fire and gas, safety etc.
- Study of the existing control systems in the plant, if any: the need for communication, and communication compatibility with the new control systems etc.
- The distances between the various control systems and interfaces.
- The type of data to be transferred between the various distributed control systems, i.e. critical or non-critical, and the type of inputs/outputs.
- Communication compatibility between the various control systems available in the market.
- Control system services available, based on the geographical location of the plant.
- Integration with plant management and asset management systems, if any.
- Maintenance/diagnostic requirements, and the availability of skilled resources for smooth plant operation.
- Required speed of the communication protocol, based on the type of processes.
- Software and hardware requirements etc.
The selection process highly recommends close interaction with the plant owner/client about their requirements and available resources. This will ensure a more appropriate selection of the control system communication protocols required in the plant.
Conclusion
All these open communication protocols can help plant owners obtain the absolute status of the plant at any time very easily. This reduces maintenance cost and unplanned shutdowns, and helps to increase production volume. Plant owners should come forward for value-added, latest communication technologies, for better process control and management and to encourage further technological advancement.
Bibliography
Books and references:
- Guidelines for planning and commissioning PROFIBUS DP/PA, by Endress+Hauser
- System engineering guidelines, by the Fieldbus Foundation
- Modicon Modbus Protocol Reference Guide PI–MBUS–300 Rev. J
- DeviceNet Media Design and Installation Guide, by Rockwell Automation
- Process Control, by Béla G. Lipták
Web references:
- http://www.taltech.com/datacollection/articles/serial_intro
- http://www.simplymodbus.ca/FAQ.htm#Modbus
- http://machineryequipmentonline.com/electric-equipment/field-interfaceshighway-addressable-remote-transducer-hart
- http://www.smar.com/en
- http://www.smar.com/en/technical-article/wireless-isa-100
- http://www.pepperl-fuchs.com/global/en/10028.htm
- http://www2.emersonprocess.com/siteadmincenter/PM%20Central%20Web%20Documents/EMR_WirelessHART_SysEngGuide.pdf
Abbreviations and meanings
- Syntax: the structure of a sentence.
- Semantics: the meaning of a word, phrase or text.
- Topology: the way in which things are interrelated or arranged.
- RTU: Remote Terminal Unit. An RTU is a device installed at a remote location that collects data, codes the data into a transmittable format and transmits it back to a central station, or master. An RTU also collects information from the master device and implements the processes directed by the master. RTUs are equipped with input channels for sensing or metering, output channels for control, indication or alarms, and a communications port.
- Ethernet: a family of computer networking technologies commonly used in local area networks (LANs) and metropolitan area networks (MANs).
- TCP/IP: Transmission Control Protocol/Internet Protocol, the suite of communications protocols used to connect hosts on the Internet.
- Open protocol: a free protocol that manufacturers can build into their equipment without paying royalties.